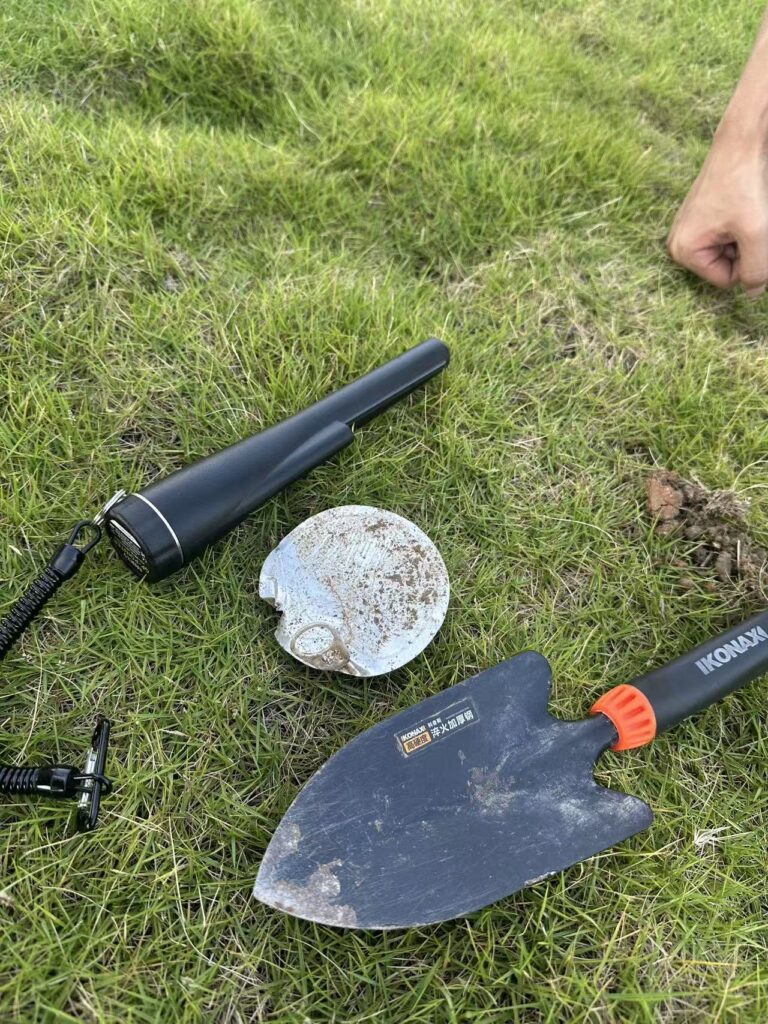
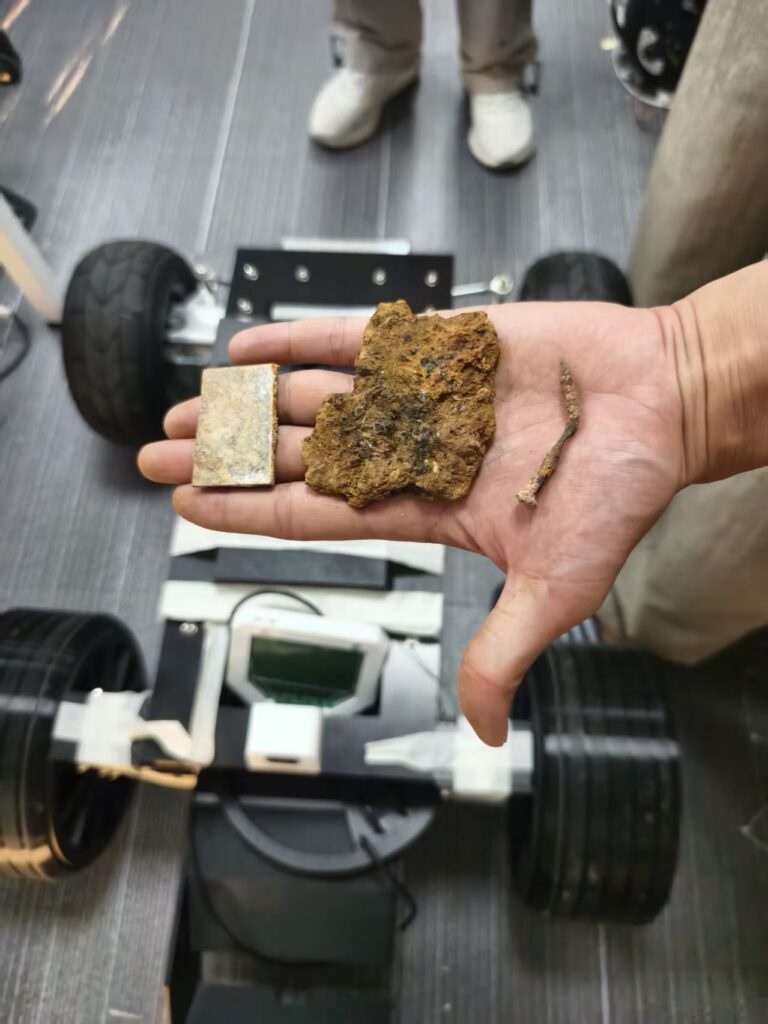
2026.10.09The items retrieved during the test of the new chassisAutonomous metal detecting rover
We cover
You discover
A metal detecting robot built to cover more ground, so you have more chances to make the find
Why SandWorm
More ground
More chances
SandWorm handles systematic coverage while the detectorist stays focused on signals, judgement and the moment of discovery.
Grid scanning
Autonomous routes reduce repeated passes and help cover a designated area systematically.
All-terrain mobility
mobility is being prepared for mixed terrain field tests across sand, dirt and grass.
Coin detection depth
SandWorm can detect a coin buried 20 cm underground, helping you find metal targets beneath the surface. Actual detection depth varies with soil conditions, target material, and environmental interference.
Field test records
Every inch.
All terrain.
Real footage from our field tests. A metal-detecting rover that sweeps a precise grid on its own and takes on any surface, from sand to dirt to rock.
Dev Log
Built in the field, one prototype at a time.
Read the development log, current limits and roadmap before you decide whether SandWorm fits your search.
2026.10.09The items retrieved during the test of the new chassis
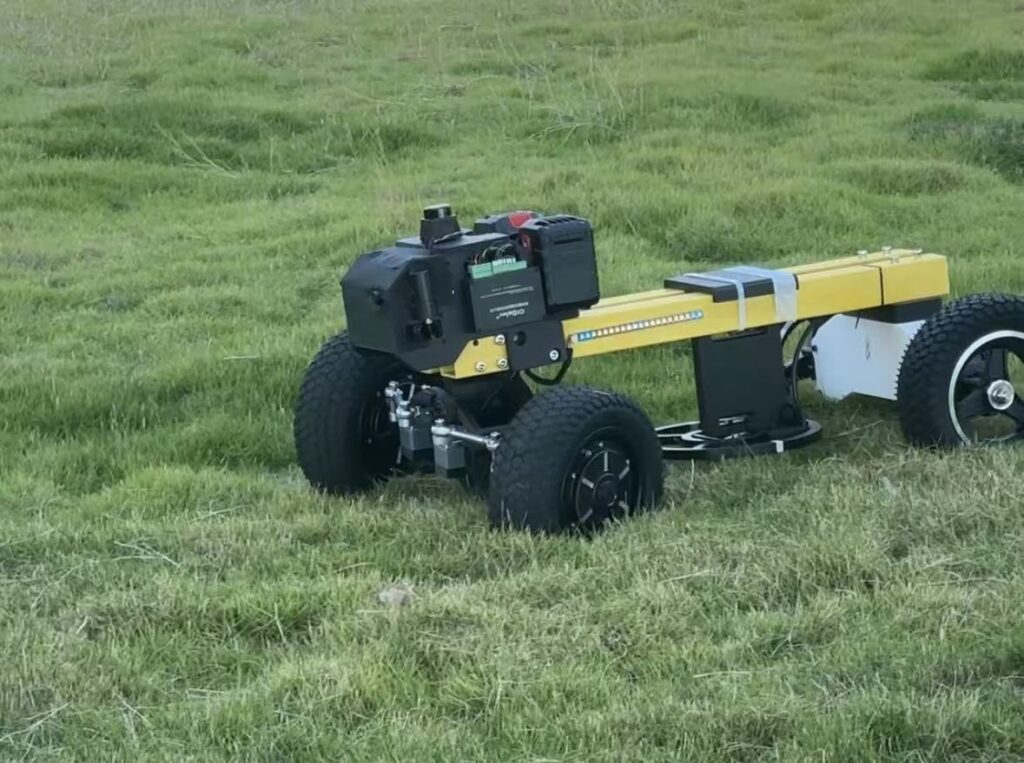
2026.10.08Test results of the new chassis.
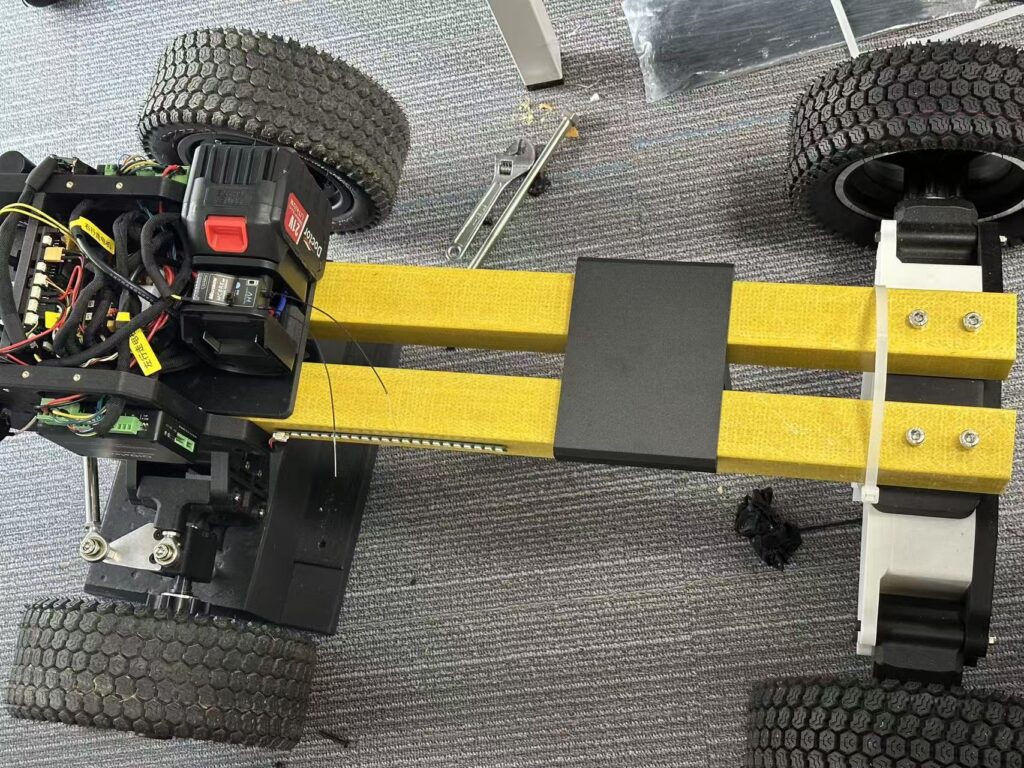
2026.09.25A new generation of territory is being assembled.
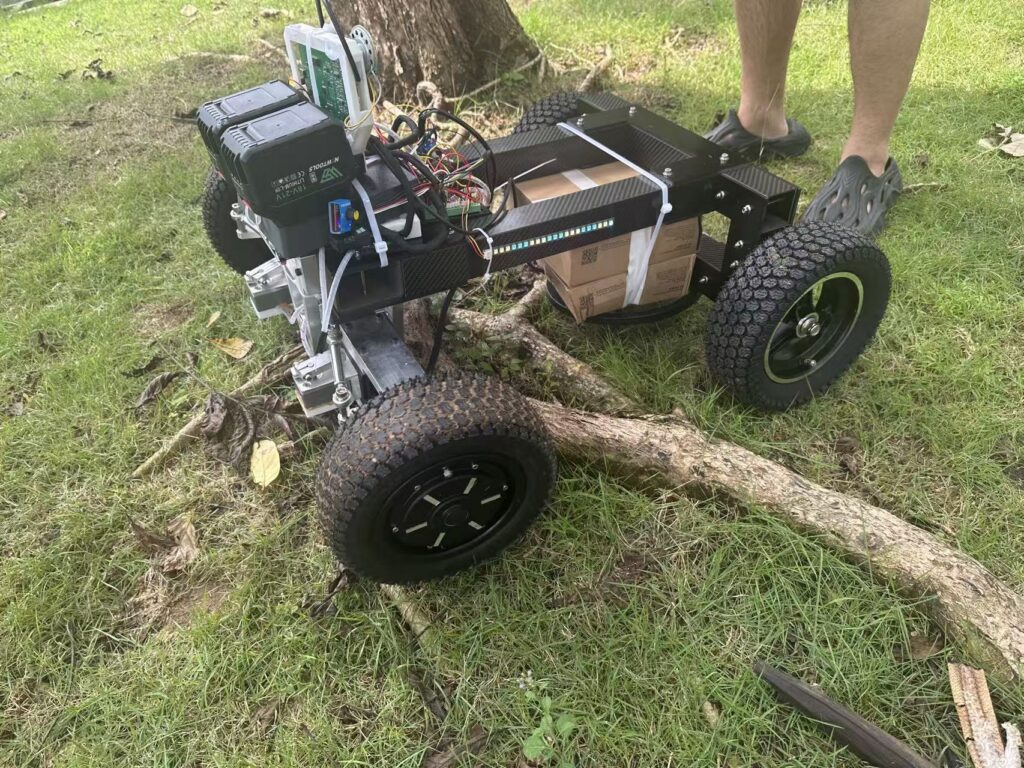
2026.09.03Development Log # 4: Low Speed Barriers Improved through Capability
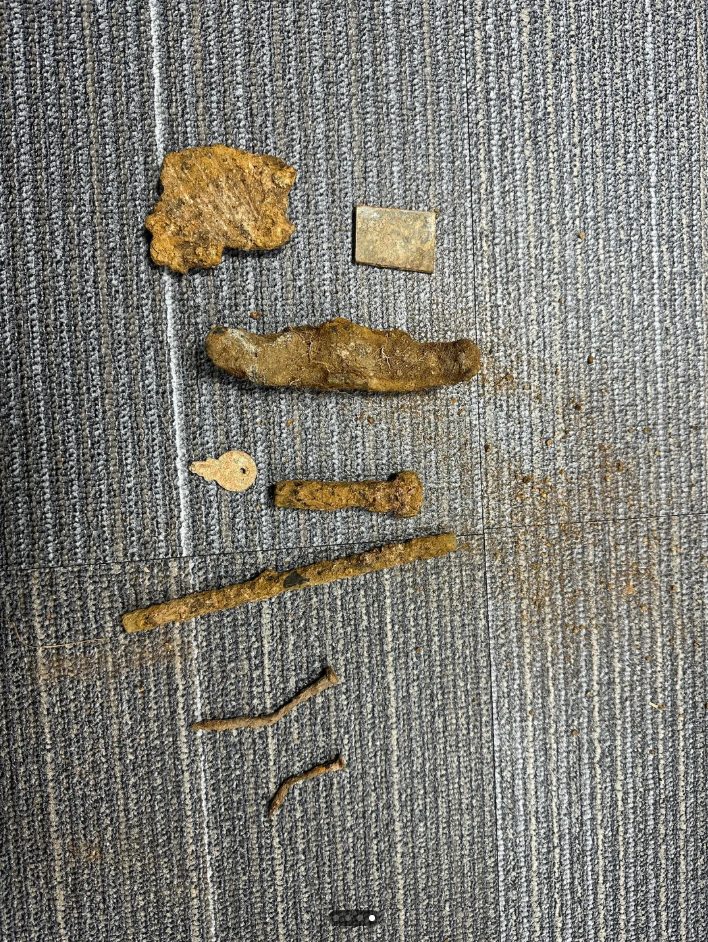
2026.08.25Show us what we dug up during our tests.
2026.08.21Development Log #3: The interference issue has been resolved, and preparations are underway for field testing.Early access — Support
Test it first.
Back the build.
Join us early.
Two ways to get involved: run SandWorm on your own ground as an early field tester, or help fund the next prototype. Testers get first access — supporters get every update from the bench.