First-ever test drive of the second-generation prototype aircraft.
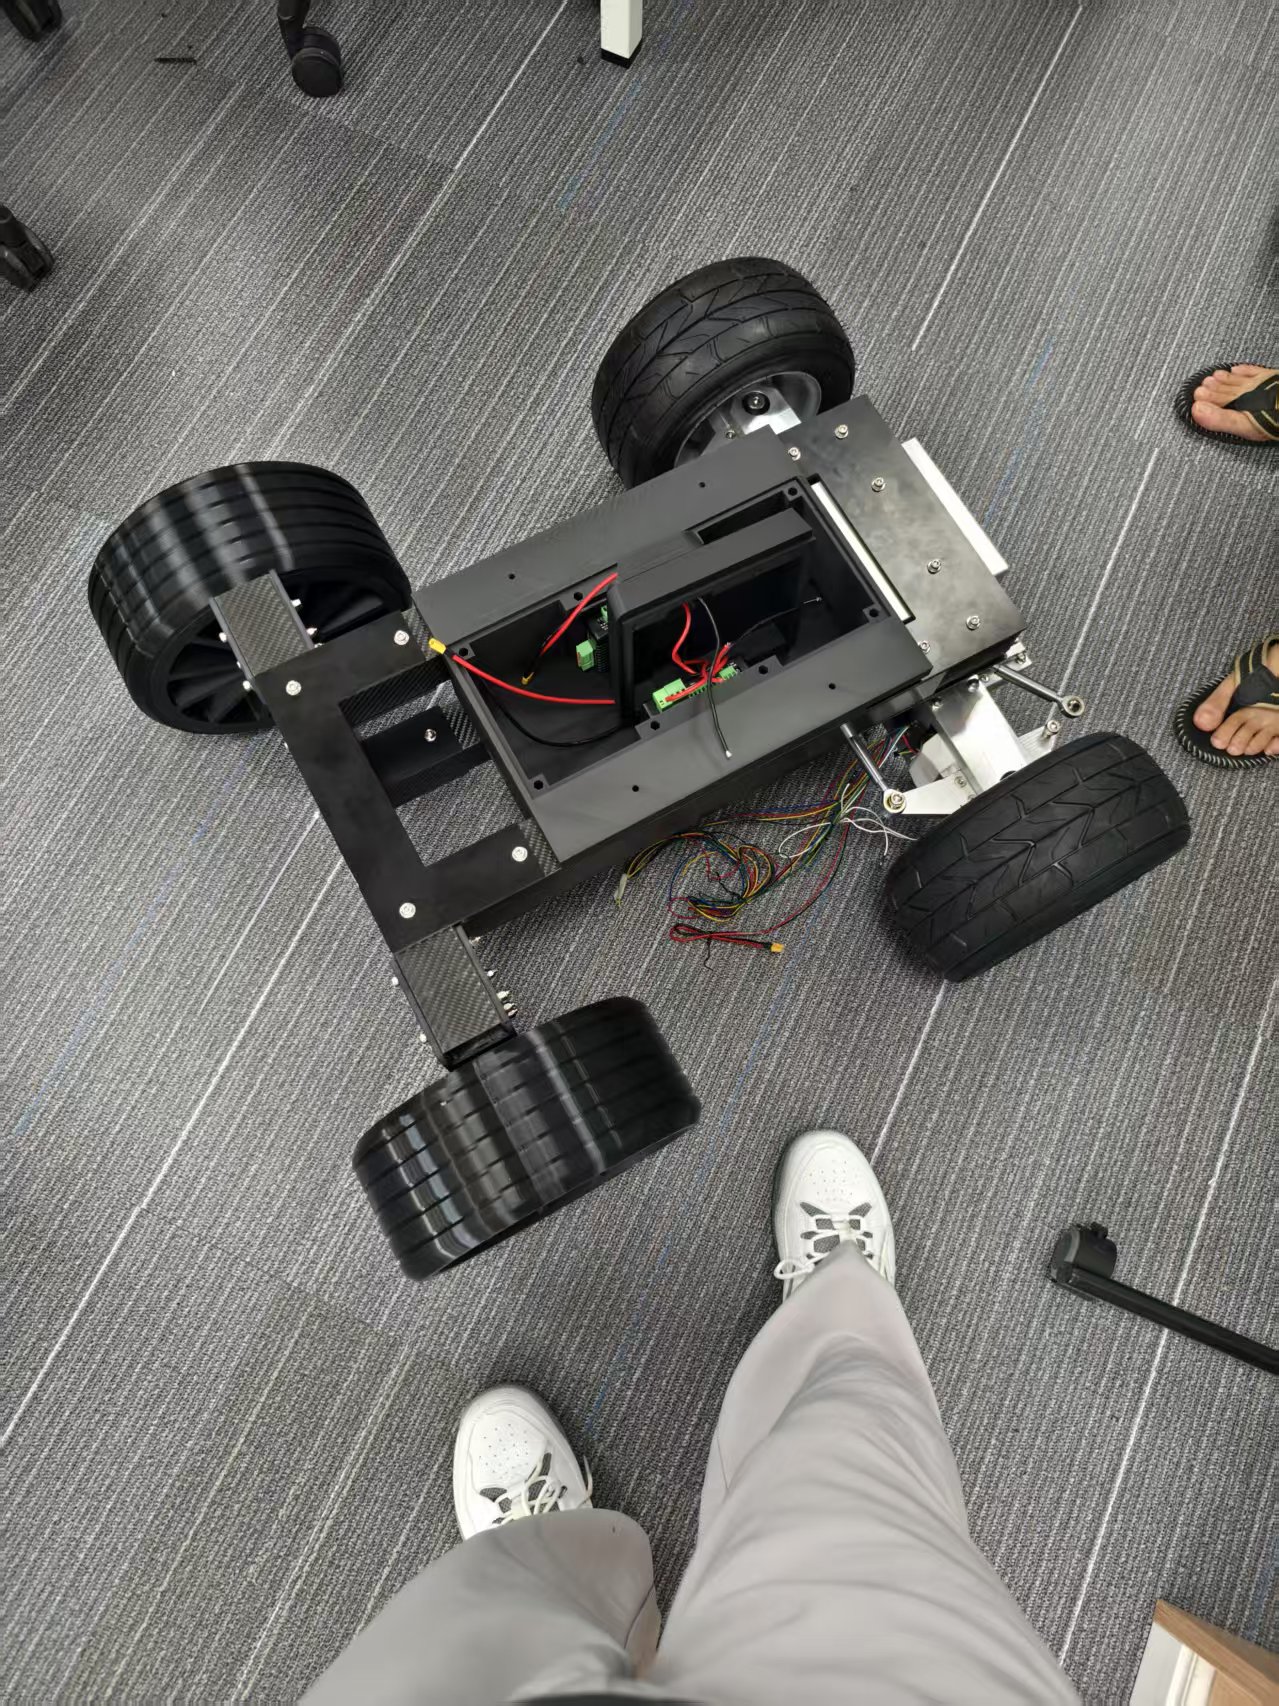
We recently completed the first mobility performance test of the second-generation SandWorm exploration vehicle. The objective was straightforward: to take a prototype equipped with a new wheel-based chassis onto real terrain and assess its handling characteristics before installing any exploration hardware.
Test content.
The Gen 2 platform features a redesigned wheel-driven system designed to enhance mobility on mixed terrains. We brought it to a nearby testing area that included grass, compacted soil, and various uneven sections to assess basic movement, stability, and steering performance.
Issues identified.
The exploration vehicle performed well while driving in a straight line, able to navigate moderately bumpy terrain smoothly. However, we soon discovered limitations in the steering system – the turning radius was much larger than expected, and it was difficult to smoothly make sharp changes in direction. In confined spaces, the vehicle was unable to effectively adjust its position, which could pose problems in actual searches.
Future plans.
The primary task currently is to modify the steering geometry and control logic to enable the detection vehicle to achieve smaller and more predictable turning radii. Once this issue is resolved, we will move on to the integration phase of the metal detection system. Further developments will be continuously updated in the log.
Follow the build as it happens.
Early testers run the prototype on their own terrain and get first access to results. If you would rather back the build, the support page explains where the money goes.